Current Opportunites
Wearable Rehab Suit
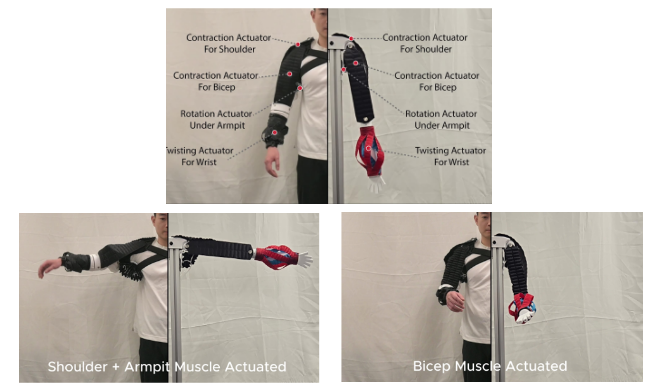
Description: We are developing a suit that organizes fabric-based pneumatic actuators into distinct muscle groups, pressurized independently or in coordination, so assistance can be targeted to a specific motion and user, for both strength augmentation and rehabilitation. We have developed a new actuator that achieves full shoulder abduction on its own. Taking the actuator shown from a working single unit to a complete wearable system. This includes fabricating and iterating actuator units, integrating them into a wearable garment that anchors reliably to the body, building the pneumatic and electronic control hardware to drive multiple actuator groups, and running benchtop and on-body characterization to quantify the assistance delivered.
Desired skills: 1. Strong hands-on fabrication and rapid prototyping skills, fabric-based fabrication (patterning, sewing, heat sealing), 2. Electronics and pneumatic control (valves, pressure sensing, microcontrollers), basic coding, design of experiments and data analysis. 3. Previous experience with soft robotics or wearable devices preferred. 4. Previous experience with IRB and human subject testing is helpful
Desired start date: 10/15/26
Hours: ~20 per week
Compensation: Course credit (ME 390/490/590) or voluntary
Application deadline: 10/15/26
For questions, contact Richard Li (richieli@umich.edu)
APPLY HERE